

 By ATN Editorial Team
Summary: Porsche, Volkswagen Group brands and CARIAD announced at NVIDIA GTC Berlin that they are jointly building a shared AV data flywheel, with Porsche leading the initial implementation and ecosystem integration together with NVIDIA, Microsoft and Voxel51. The AV data flywheel is a reference architecture that connects real-world fleet data to simulation, training and validation, drawing on a Volkswagen Group fleet that generates data equivalent to 11,000 average drivers per day.
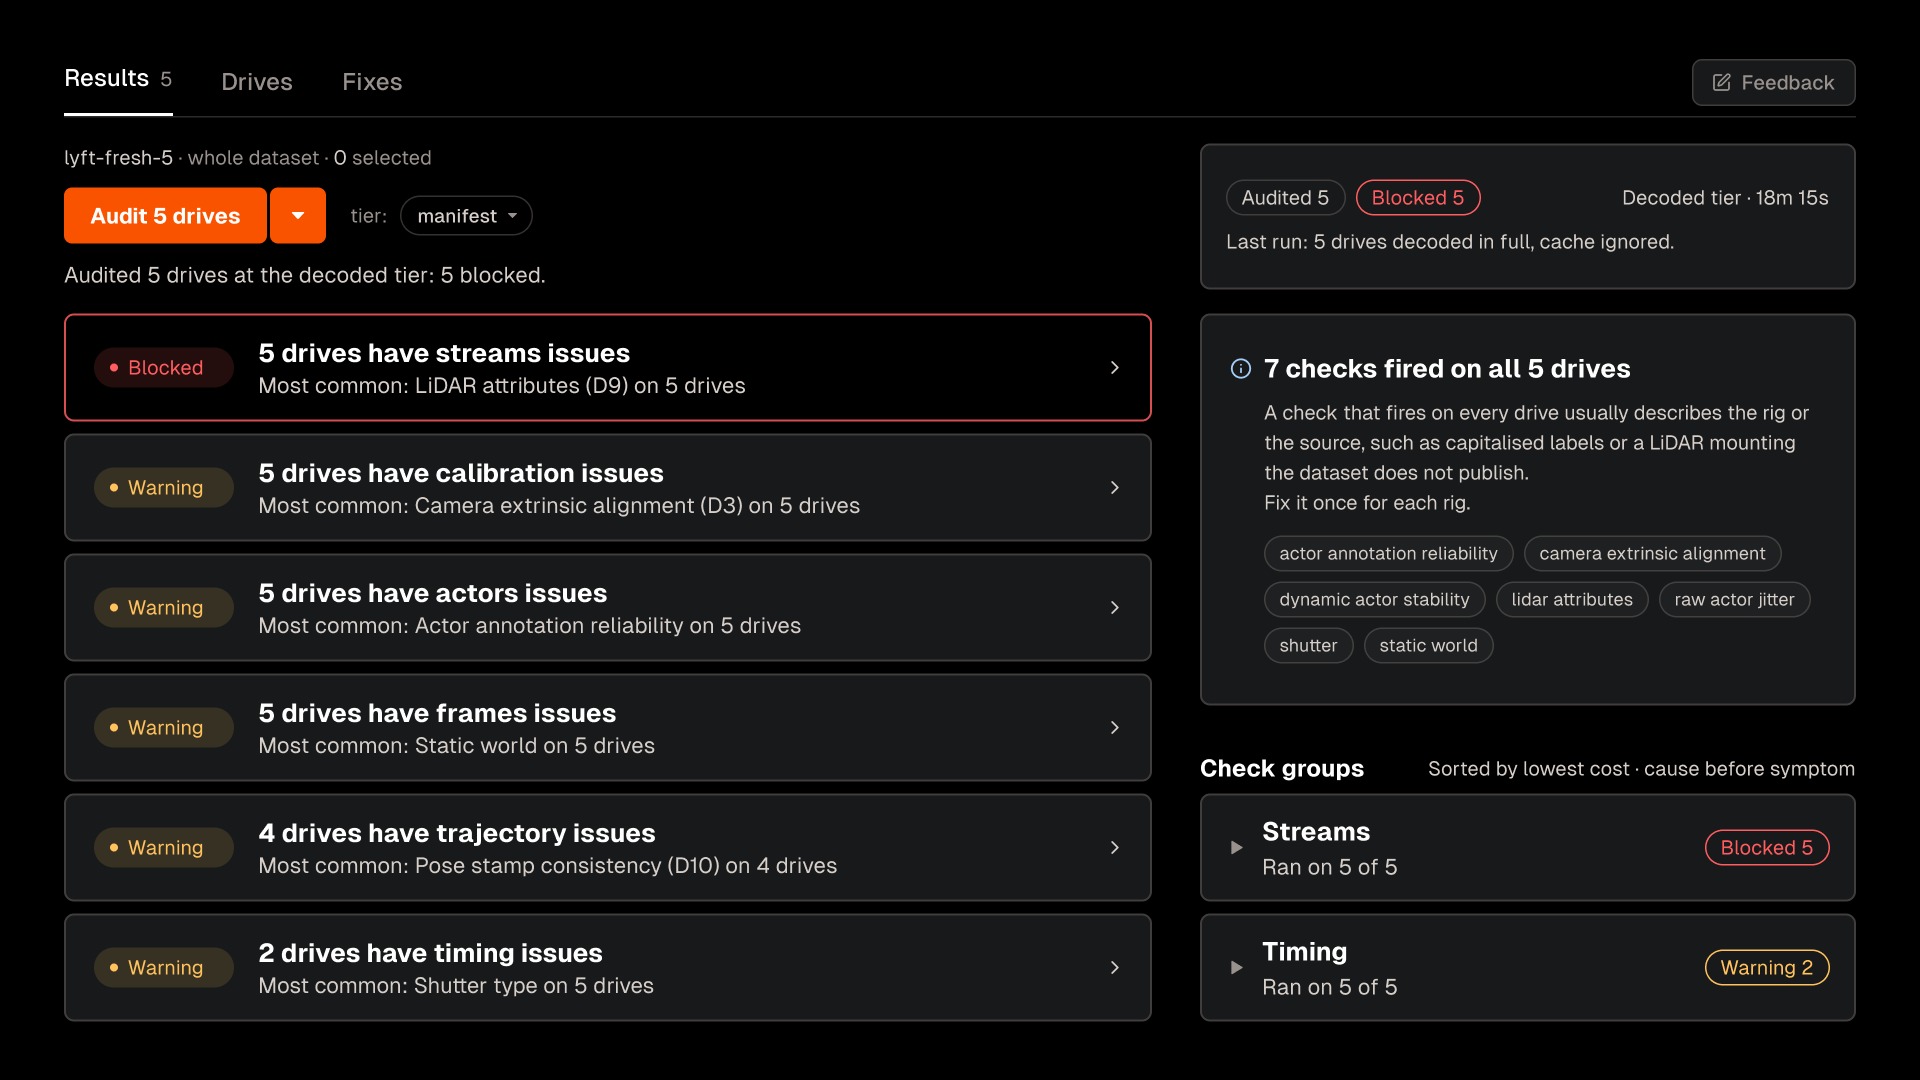
Key engineering takeaway: Before a drive is used for reconstruction, Voxel51 audits the raw recording, reading MCAP files directly, across roughly 80 checks covering sensor integrity, timing, calibration, trajectories, actors and coordinate frames, and each check records whether it passed, failed or could not run so that missing inputs are not mistaken for valid data. Reconstructions made with NVIDIA Omniverse NuRec are then scored by camera and object class, with separate checks for vehicles and pedestrians, before engineers approve them for simulation, route them back for retraining or reject them.
Why it matters: Virtual validation of driving-software releases on reconstructed drives is one of the first applications of the AV data flywheel for Porsche and the Volkswagen Group, with the aim of making testing repeatable, shortening feedback cycles and reducing dependence on physical test drives. The collaboration is expected to reduce repeated physical test drives by up to 90% and shorten AI regression test cycles by up to 85%.
New reference architecture for AV connects real-world fleet data to simulation, training, and validation. The collaboration is expected to reduce repeated physical test drives by up to 90% and shorten AI regression test cycles by up to 85%.
At NVIDIA GTC Berlin, Porsche, Volkswagen Group brands, and CARIAD announced that they are jointly building a shared AV data flywheel, with Porsche leading the initial implementation and ecosystem integration together with NVIDIA, Microsoft, and Voxel51. With a fleet generating data equivalent to 11,000 average drivers per day, the Volkswagen Group is leading the development of a physical AI stack that connects fleet data to simulation, training, and evaluation.
- Volkswagen is building the physical AI stack. It brings its connected fleet, real-world driving data, vehicle platform, and system requirements to build a faster development loop for advanced driving systems.
- Voxel51 provides the data layer for the flywheel. Its multimodal data platform turns raw fleet data into high-quality training and simulation inputs, then connects model failures back to the scenarios and data needed for the next iteration.
- NVIDIA provides data retrieval, generation and simulation technologies including NVIDIA Cosmos Data Factory for preparing, augmenting, and evaluating training data, NVIDIA Omniverse NuRec libraries for reconstructing real-world drives, and open models and tools for testing driving systems in simulation.
- Azure provides the infrastructure. It supplies the cloud and compute needed to run these workflows securely at fleet scale on infrastructure Volkswagen already uses.
The collaboration brings together specialized systems across the AV workflow to create a reference architecture for automakers building the next generation of advanced driving systems.
Voxel51 Data Layer For Physical AI Training Data
Automotive is one of the clearest proving grounds for physical AI. Advanced driving systems increasingly depend on models that can perceive, reason about, and act in the physical world, using data collected from real vehicles operating in complex, changing environments.
In physical AI, that makes real-world data one of an automaker’s most valuable assets. Models improve by learning from the environments and behaviors they encounter, which means vehicles on the road can contribute to a growing body of experience that is difficult to reproduce anywhere else. For automakers with large connected fleets, that data advantage compounds over time.
Voxel51 powers the following workflows in Volkswagen Group’s AV data flywheel: multimodal search and retrieval, automated labeling, scenario-based curation, dataset balancing, training data selection, and model validation.
“The key to really industry-leading performance is to harness the data that your company has access to. You need to own the development and iteration loop, even if you don’t build every layer of the stack yourself,” said Voxel51 CEO Brian Moore.
AV Data Flywheel Virtual Validation And Reconstruction Checks
For Porsche and the Volkswagen Group, virtual validation of driving-software releases is one of the first applications of the data flywheel. The team renders reconstructed camera inputs from real drives and compares simulated outputs with real-world measurements. The aim is to make testing repeatable, shorten feedback cycles, and reduce dependence on physical test drives.
Reconstruction is unforgiving. A camera calibration that’s off by a few degrees or a LiDAR clock offset won’t stop a reconstruction job. It produces a scene that scores fine and looks wrong, hours of GPU time later — with every downstream simulation inheriting that error.
So before a drive goes anywhere near a GPU, Voxel51 audits the raw recording across roughly 80 checks covering sensor integrity, timing, calibration, trajectories, actors, and coordinate frames. The audit reads MCAP files directly, and the fastest checks complete in a fraction of a second per drive, making it practical to validate data across an entire fleet.
Each check records whether it passed, failed, or could not run, so missing inputs are not mistaken for valid data. Those results determine whether a recording is suitable for downstream reconstruction and simulation, where gaps in calibration, synchronization, projection, or metadata can compromise scene fidelity.
“Simulation is transforming how autonomous vehicles are developed, turning real-world driving experience into a continuous cycle of learning and improvement,” said Rishi Dhall, vice president of automotive at NVIDIA. “With Voxel51’s data platform and NVIDIA Omniverse NuRec and Cosmos, Volkswagen Group can turn fleet data into high-fidelity simulation scenarios to accelerate the development and validation of next-generation driving systems.”
From Voxel51, engineers can launch and track NVIDIA Omniverse NuRec reconstructions and data generated from NVIDIA Cosmos runs. Each synthetic output is automatically checked for quality and remains linked to the source clip, generation recipe, and model that produced it. Completed reconstructions return with the original camera view, the rendered output, and the reconstructed 3D scene ready for the team’s simulator.
Voxel51 evaluates each reconstruction across multiple dimensions rather than collapsing quality into a single score. Image quality is measured by camera and object class, with separate checks for vehicles and pedestrians so localized failures are not hidden by aggregate metrics. Each run then enters a review queue, where engineers can approve it for simulation, route it back for retraining, or reject it.
Each stage runs as a job on Microsoft Azure, where the Volkswagen Group manages its fleet data. Azure provides the storage and compute needed to scale data processing, reconstruction, and simulation while keeping those workloads inside the Volkswagen Group’s existing security, identity, and regional governance model.
More details are available in the technical deep dive from Daniel Gural, Voxel51’s Head of Technical Partnerships.
Porsche is playing a key role in the development of a shared AV data flywheel across Volkswagen Group brands, using Cosmos Data Factory through Voxel51 on Microsoft Azure. This collaboration is expected to reduce repeated physical test drives by up to 90% and shorten AI regression test cycles by up to 85%.
Common Data Model Across Brands And Software Releases
The Volkswagen Group recognized early that the data and software development loop would become a core source of competitive advantage.
A common data model lets driving data and scenarios created in one project carry forward across vehicle programs, software releases, and brands. Over time, every new drive expands that scenario base, while reconstructed scenes can be reused across future development and validation cycles. The result is a compounding data flywheel.
For automakers, the opportunity is increasingly defined not only by how much proprietary data they have, but by how quickly they can turn what happens on the road into the next useful training, simulation, and validation workload.
AV Data Flywheel: Frequently Asked Questions
What is the Volkswagen Group AV data flywheel?
It is a shared AV data flywheel that Porsche, Volkswagen Group brands and CARIAD are jointly building, with Porsche leading the initial implementation and ecosystem integration together with NVIDIA, Microsoft and Voxel51. It is a reference architecture that connects real-world fleet data to simulation, training and validation. In it, Volkswagen builds the physical AI stack, Voxel51 provides the data layer, NVIDIA provides data retrieval, generation and simulation technologies, and Microsoft Azure provides the infrastructure.
What is a data flywheel in autonomous driving development?
In general terms, a data flywheel is a development loop in which data collected from vehicles is curated into training and test sets, models are trained and evaluated, and the scenarios where a model fails are fed back to guide the next round of data selection and training. Each cycle adds to the pool of scenarios available for the next one. The release describes this compounding effect: driving data and scenarios created in one project carry forward across vehicle programs, software releases and brands.
Why does Voxel51 audit recordings before reconstruction?
According to the release, a camera calibration that is off by a few degrees or a LiDAR clock offset will not stop a reconstruction job, but produces a scene that scores fine and looks wrong, with every downstream simulation inheriting the error. Voxel51 therefore audits each raw recording across roughly 80 checks covering sensor integrity, timing, calibration, trajectories, actors and coordinate frames before any GPU work, and records whether each check passed, failed or could not run.
What is virtual validation of driving software?
Virtual validation is the testing of driving software in simulation rather than, or before, physical test drives. In the approach described for Porsche and the Volkswagen Group, reconstructed camera inputs from real drives are rendered and the simulated outputs are compared with real-world measurements, with the aim of making testing repeatable, shortening feedback cycles and reducing dependence on physical test drives.
What are MCAP files?
MCAP is an open-source container file format for storing multimodal, timestamped log data, such as camera, LiDAR and other sensor streams, in a single recording. It is widely used for robotics and autonomous vehicle data logging. In the AV data flywheel, Voxel51’s audit reads MCAP files directly.
Further Reading
- VI-grade And Aidoptation Partner On Autonomous Driving Validation
- PTV Vissim Traffic Simulation Integrates With rFpro For ADAS
- BMW Image Data Collection Expands Across EU Customer Cars
- NVIDIA Launches Alpamayo 2 Super Reasoning Model For Robotaxis
For more simulation news, click here.
